Engineering blog Post 02
Satellites and simulators as robots: Strands Robots runtime adapters
Strands Robots (strands-labs/robots) is an open-source library that turns robots and simulators into tools a Strands agent can call.
We use a fork of it under the Agentic Operations Stack, and we contribute changes back upstream.
Why treat a spacecraft as a robot
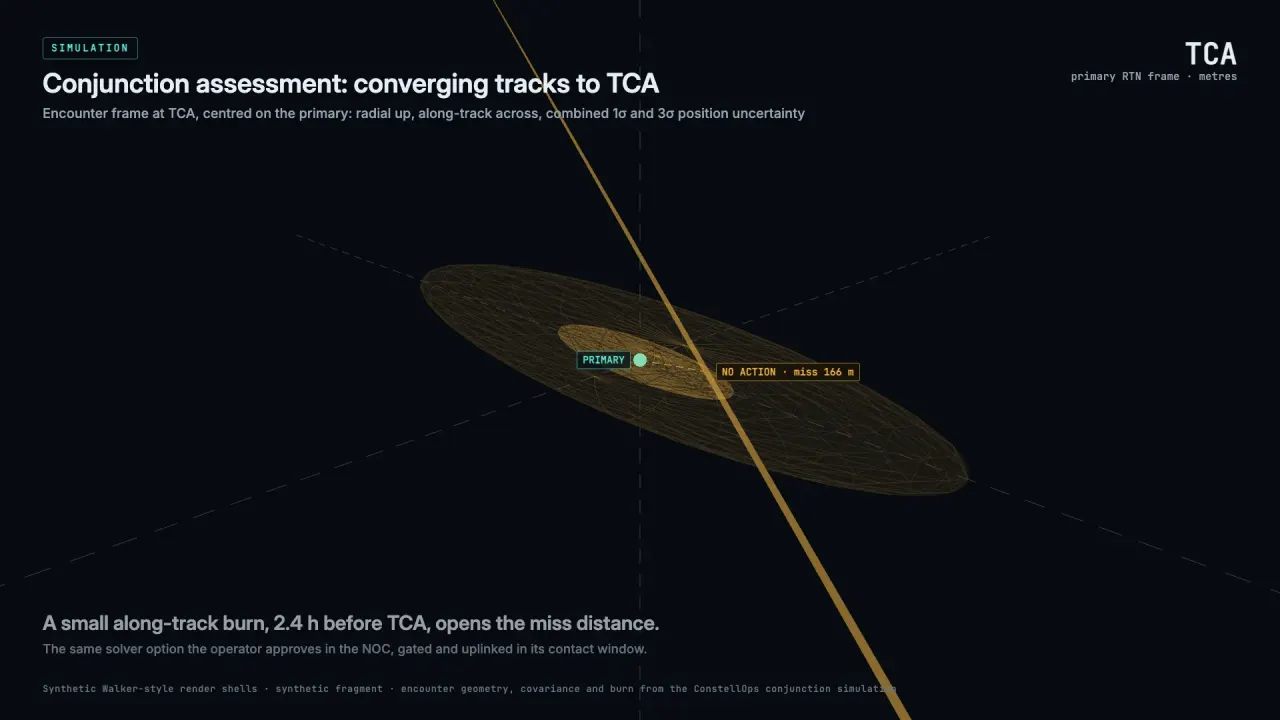
An operations agent needs the same things from a satellite that a robotics agent needs from an arm: observe state, propose an action, have the action checked, send it, observe again.
The differences are physics and the link. A spacecraft is only reachable in contact windows, and a wrong command can cost the mission.
So we did not build a parallel framework. We put spacecraft behind the same interface as every other robot, and put the gate chain in front of anything that can move hardware.
In this post a runtime adapter means one of the two seams Strands Robots already has: a simulation backend, or a hardware driver.
Two seams, many bodies
Simulation backends implement the library's SimEngine interface. The Stack registers three: sgp4 for orbit propagation, bsk for Basilisk spacecraft dynamics, and nos3 for NASA's flight-software simulator.
The nos3 backend observes only; commanding goes through the gated path.
Hardware drivers implement the HardwareDriver seam. The spacecraft driver refuses any action with no clearance, and the transport behind it refuses one that is invalid, expired or reused. A ground-station driver sits beside it.
The result is one call shape for all of them: Robot("sat-001", backend="nos3", …) or a real asset, behind the same tool interface.
Backends by entry point
We wanted the Stack to extend Strands Robots without patching it. The library discovers simulation backends through a Python entry-point group, so the Stack declares its own:
[project.entry-points."strands_robots.backends"]
sgp4 = "aos.sim.sgp4_backend:Sgp4SimEngine"
bsk = "aos.sim.bsk_backend:BskSimEngine"
nos3 = "aos.sim.nos3_backend:Nos3SimEngine"
On the first lookup the factory scans the group once and loads every plugin, caching the result. Built-in backends win a name clash, and a plugin that fails to load is logged and skipped rather than taking the rest down.
Upstream: rosbridge and the Curiosity rover
Not all of the work was about space. Two contributions to Strands Robots are merged:
- strands-labs/robots #1110, merged: a rosbridge transport. An agent can drive ROS 1 robots, or robots on machines with no ROS install, over rosbridge's JSON-over-WebSocket protocol. It was verified live against the NASA Curiosity Mars rover simulation in Gazebo.
- strands-labs/robots #995, merged: ROS 2 action support, so an agent can send goals such as a navigation goal, not only topics and services.
Smaller merged changes include a simulation capabilities query (#4177) and registering a robot with no simulation asset (#4232).
Five more are merged too: an off-policy reinforcement-learning provider (#3206), a dashboard kill switch and e-stop (#3205), and three smaller interface fixes (#4270, #4176, #4175).
Robot APIs that do not fit orbits
Some of the robot interface assumes joints. A spacecraft has none in that sense.
Rather than fake them, the orbital backends refuse joint-space calls, and the spacecraft driver answers joint-space tasks and policies with an explicit "unsupported".
That is the general rule we followed: when an abstraction does not fit, refuse clearly instead of approximating.
An agent that gets "unsupported" can say so. An agent that gets a made-up joint state can be wrong without knowing it.Link to this quote
What went wrong
Next pass
A spacecraft is a robot you can only reach during a pass. Treating it as one meant every safety property of the gate chain applied to orbit and to flight software without a parallel framework.
Post 3 takes that path onto real cFS.